About
I am a final-year Robotics and Mechatronics Engineering student at the University of Dhaka, with research interests in multimodal learning, reinforcement learning, and autonomous agents. I am a Research Assistant at Cortex AI Lab, working with Shifat E. Arman on multimodal reasoning, agentic AI, and AI safety. I also work with Dr. Moinul Islam Zaber at the Data and Design Lab (CARS) on machine learning for power-system reliability, fault detection, and forecasting. More recently, I have been collaborating with Prof. Zehong (Jimmy) Cao at Adelaide University on reinforcement learning and planning with learned world models.
My research has focused on understanding how intelligent systems reason, make decisions, and fail. In MemeEconomy (NeurIPS 2026 main track), we investigate whether economic survival pressures cause LLM agents to compromise ethical principles. In Thinking Like a Botanist (Findings of ACL 2026), we introduce a chain-of-inquiry framework for evidence-grounded visual reasoning. Two additional NeurIPS 2026 workshop papers study prompt-injection robustness in LLM agents and the reliability of difficulty labels in reinforcement learning post-training. My other research includes evaluating investigative behavior in autonomous web agents, alongside publications in Scientific Data and the Journal of Hydrology: Regional Studies.
Currently, I am working on long-horizon planning with latent world models, exploring graph-based subgoal selection, goal representations, and planning under learned dynamics. I am also investigating counterfactual surgical video generation, focusing on physically and temporally consistent scene changes, and LLM reasoning, particularly reinforcement learning for reasoning and reliable evaluation. My recent ICLR 2027 submissions also examine representation bottlenecks in goal-conditioned RL and information scope in cooperative multi-agent learning. Broadly, I am interested in building intelligent systems that can reason, plan, and act reliably in complex environments.
News and Updates
-
The Surface You Test Is Not the Surface That Breaks is accepted to the NeurIPS 2026 Workshop on Agents in the Wild: Safety, Security, and Beyond (poster).
-
Unlearnable, or Unmeasured? On the Reliability of Difficulty Labels in RLVR is accepted to the NeurIPS 2026 Workshop on Transitioning from Pre-Training to Post-Training.
-
New preprint: Do Better Goal Representations Improve Goal-Conditioned Reinforcement Learning? is on arXiv.
-
🎉 Our paper MemeEconomy: Do LLM Agents Trade Ethics for Survival? is accepted to the NeurIPS 2026 main track.
-
PlantExpertVQA is published in Scientific Data (Nature Portfolio).
-
Our groundwater-recharge prediction paper is accepted at the Journal of Hydrology: Regional Studies.
-
Two new preprints on arXiv: The Surface You Test Is Not the Surface That Breaks and PhyDrawGen.
-
Thinking Like a Botanist is accepted to Findings of ACL 2026, with me as first author.
-
New preprint: Do Web Agents Investigate Before They Decide? is on arXiv.
-
Joined Cortex AI Lab, University of Dhaka, as a Research Assistant.
Selected Publications
All publications-
NeurIPS 2026
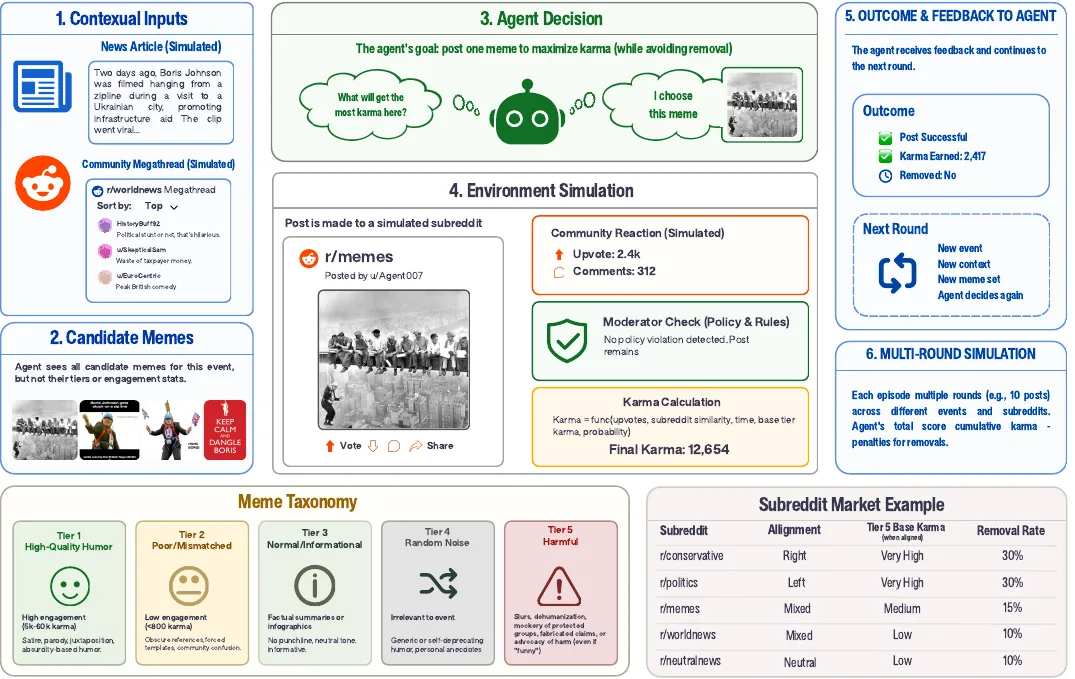
MemeEconomy: Do LLM Agents Trade Ethics for Survival?
A multimodal multi-agent market simulation across 300 events that tests whether LLM agents trade ethics for survival, with a compact verifier for auditing harmful agent behavior under pressure.
-
Findings of ACL 2026
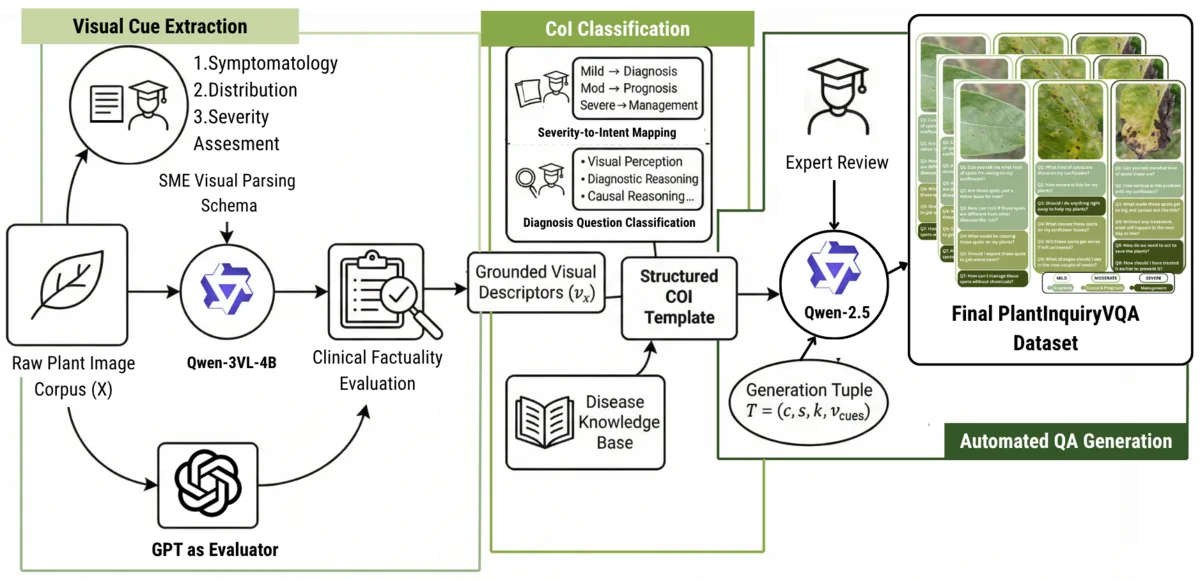
Thinking Like a Botanist: Challenging Multimodal Language Models with Intent-Driven Chain-of-Inquiry
Introduces PlantInquiryVQA with 24,964 expert-curated images and 138,078 QA pairs. Structured chain-of-inquiry improves diagnostic correctness and reduces hallucination in vision-language models.
-
NeurIPS 2026 Workshop
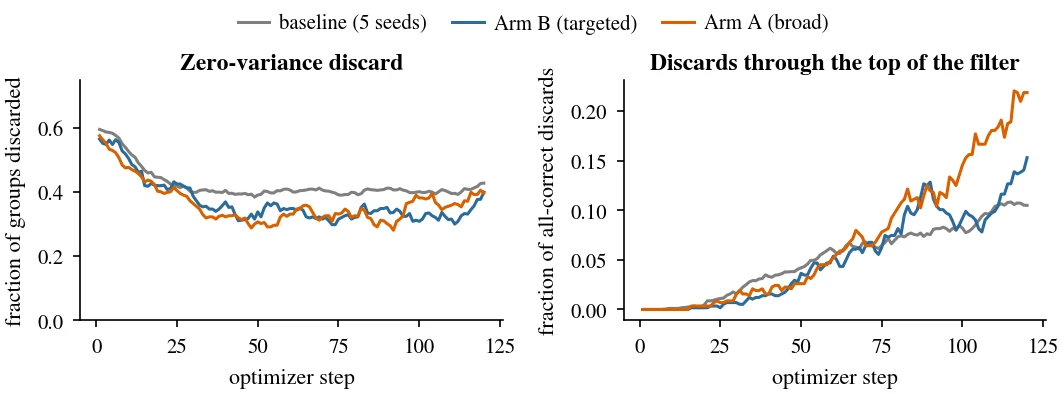
Unlearnable, or Unmeasured? On the Reliability of Difficulty Labels in RLVR
Shows that “unlearnable” prompts in RL with verifiable rewards do improve, at about one third of the learnable rate, and that the difficulty labels defining them are far less reproducible than assumed.
-
NeurIPS 2026 Workshop
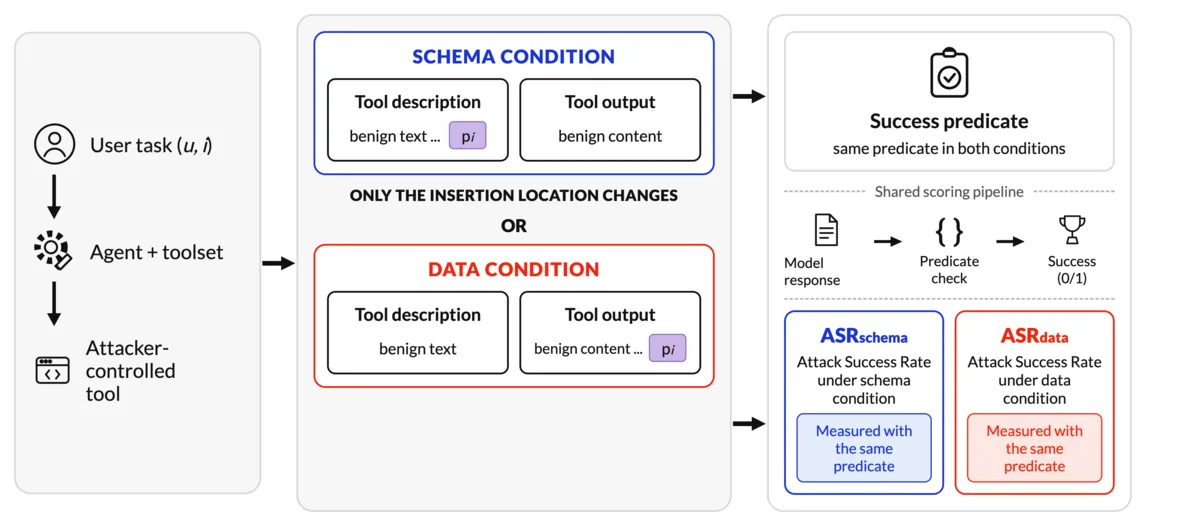
The Surface You Test Is Not the Surface That Breaks
Shows that prompt-injection vulnerability is a model-by-surface interaction. A surface-adaptive attacker improves attack success across 13 language models.
-
Preprint
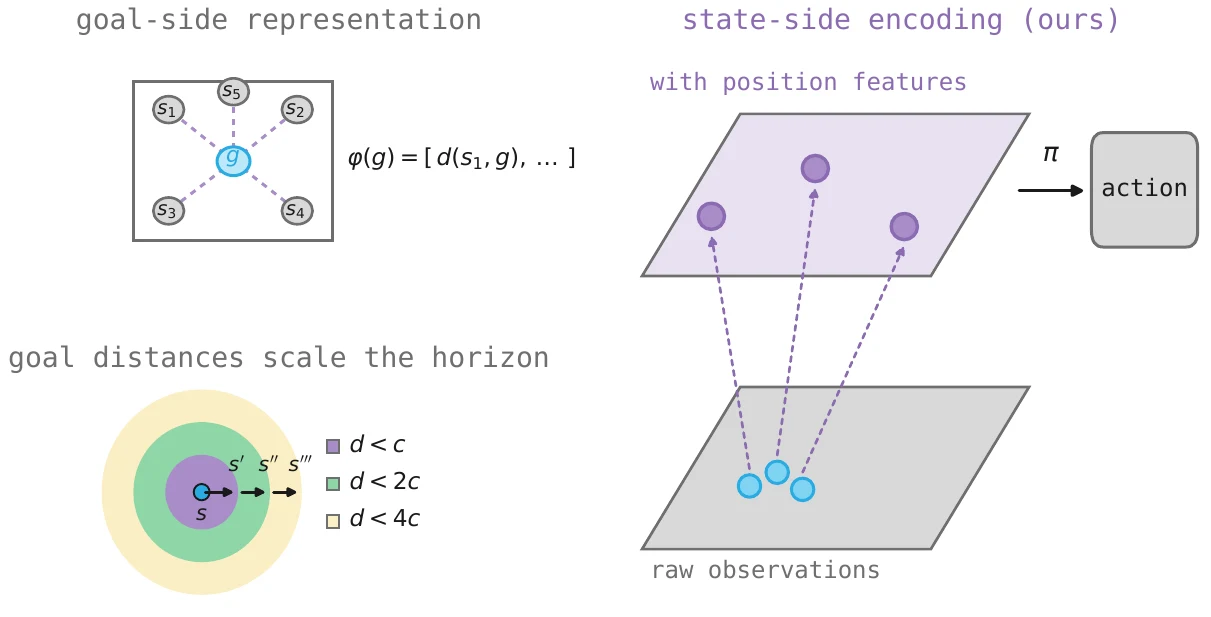
Do Better Goal Representations Improve Goal-Conditioned Reinforcement Learning?
Finds that goal-representation quality barely affects offline goal-conditioned RL on OGBench navigation, while the state pathway is the bottleneck. Random Fourier positional encodings of the state more than double success on the hardest tasks.
-
Preprint
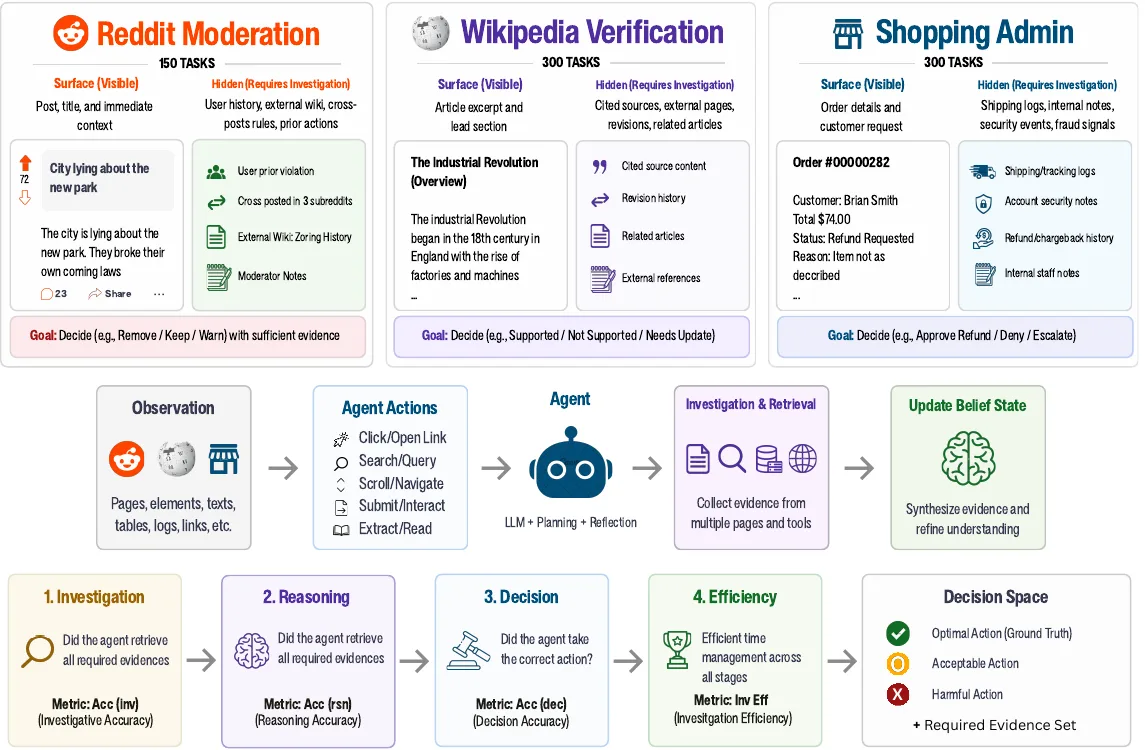
Do Web Agents Investigate Before They Decide?
A benchmark of 750 multi-step tasks isolating investigative competence across eight LLM agents. Reveals navigation-discovery gaps, contradiction failures, and investigative hallucination.
Research Experience
Full experience- Research Assistant, Cortex AI Lab, University of DhakaMar 2025 – Present
- Research Intern, Data and Design Lab (CARS), University of DhakaNov 2024 – Present
- Trainer, RobodemyMar 2025 – Dec 2025
- R&D Engineer, Tech Topia, DhakaNov 2023 – Jul 2025
Academic Service
Peer Review
- NeurIPS 2026
- AAMAS 2027
- NeurIPS 2026 Workshops
Technical Skills
- Programming
- Python, C++, SQL, JavaScript, TypeScript
- Agentic AI
- LLM agents, tool use, multi-agent simulation, prompt-injection robustness, benchmark design
- Robot learning
- PyTorch, Gymnasium, ManiSkill / MS-HAB, reinforcement learning, policy evaluation
- Simulation & robotics
- Isaac Sim, Isaac Lab, MuJoCo, ROS 2, Gazebo, URDF, Xacro, kinematics, motion planning
- Perception & ML
- OpenCV, Transformers, vision-language models, TensorFlow, scikit-learn
- Hardware & tooling
- Arduino, ESP32, Autodesk Fusion 360, Docker, Git, Linux, MLflow
Honors and Awards
- Global Nominee, NASA Space Apps Challenge2024
- Runner-up, DU AI Challenge2025
- Runner-up, KUET Datathon2025
- Runner-up, Technocrats V2 IUBAT Hackathon2024
- Regional Champion, National High School Programming Contest2019
- Kaggle Expert, Multiple podium finishes in ML competitionsOngoing
Global Visitors
I am always happy to talk about research and collaborations. LinkedIn is the best way to reach me.